
01 / UPPER BODY
Upper body
Two 7-DOF arms with 14 joint motors, an 840 mm working radius and a 5 kg payload per arm. OmniPicker grippers are standard, with dexterous hands as an option. Head and wrist RGB-D cameras provide vision for manipulation.
LAJIU R&D / WHEELED HUMANOID ROBOT
A dual-arm wheeled humanoid robot developed by Lajiu. Two 7-DOF arms, a lifting column and a mobile base cover working heights from 0 to 2,088 mm. Teleoperation data collection, VLA model fine-tuning and on-robot deployment are supported for handling, sorting, inspection and embodied-AI development.
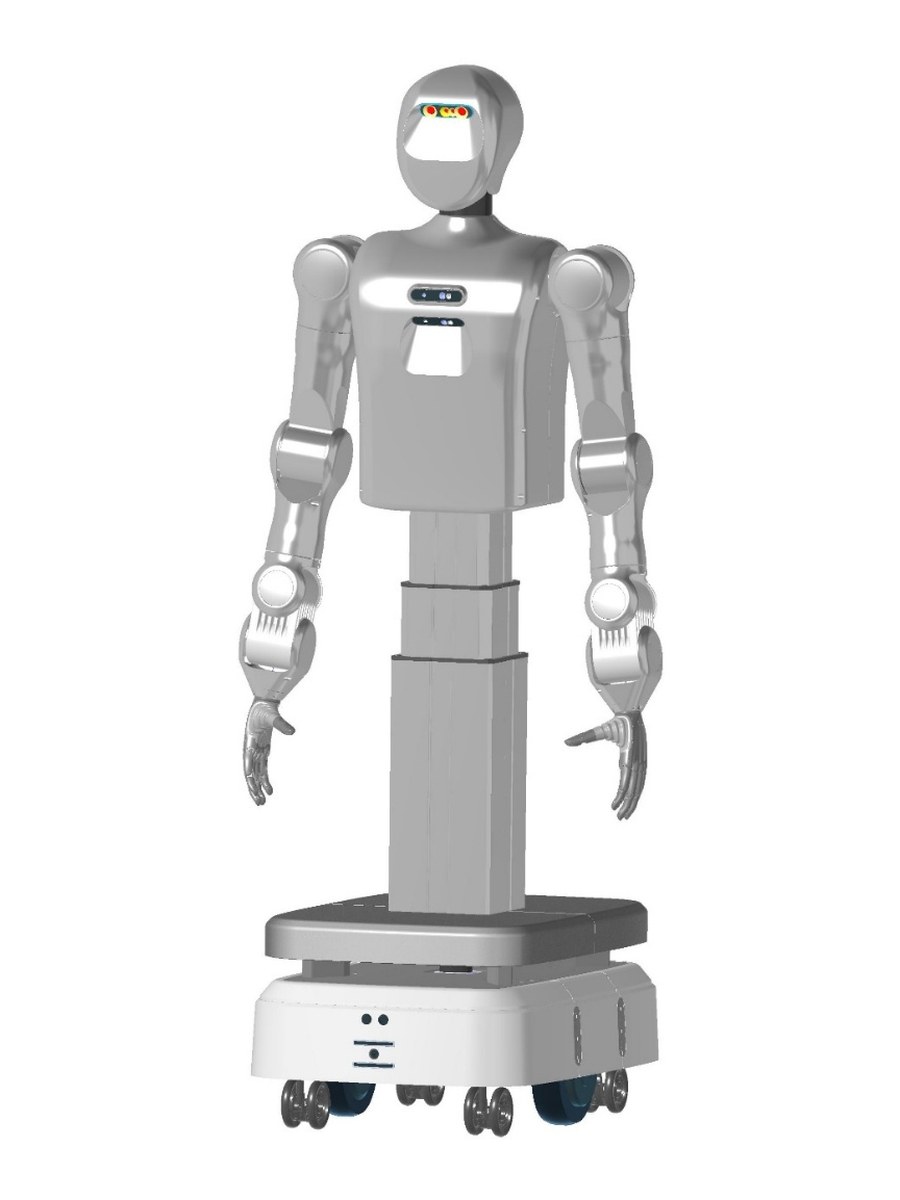
ARCHITECTURE
Upper body, column and base work together for coverage and working height.
01 / UPPER BODY
Two 7-DOF arms with 14 joint motors, an 840 mm working radius and a 5 kg payload per arm. OmniPicker grippers are standard, with dexterous hands as an option. Head and wrist RGB-D cameras provide vision for manipulation.
02 / LIFTING COLUMN
A 400 mm stroke at 55–80 mm/s with 1 mm accuracy adjusts the working height to the bench. Overall height ranges from 1,395 mm to 1,795 mm.
03 / MOBILE BASE
Navigation fuses lidar and RGB-D cameras. The base travels at up to 1.2 m/s, passes 63 cm aisles and climbs 10° slopes; the lithium battery supports automatic recharging.
DEMONSTRATIONS
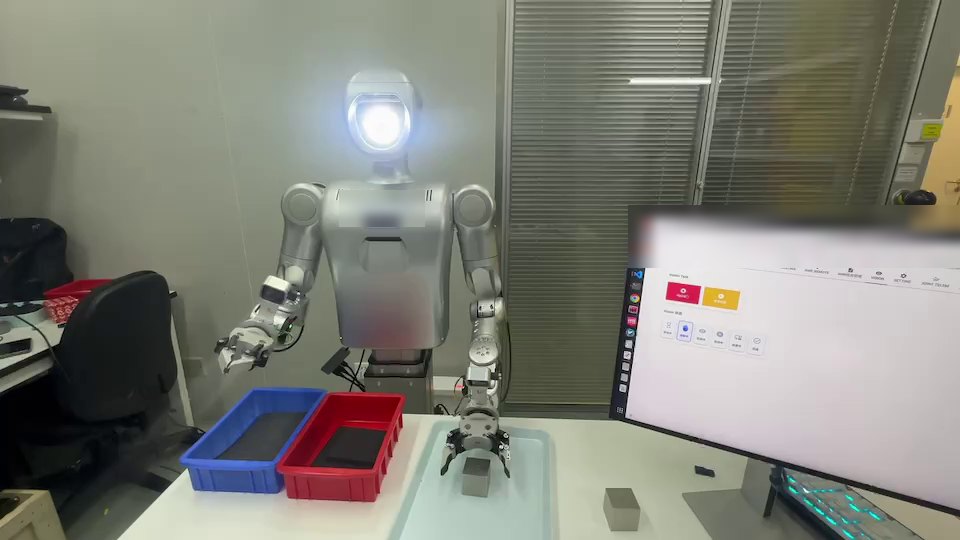
Research-test footage; people and third-party marks are blurred.
The robot moves to a workbench, picks up items and places them in a tote.
Parts are placed into separate colour-coded bins, with the web operator interface alongside.
The arms pick up a towel and place it in a container.
APPLICATION REVIEW
Share the objects, workstation layout and cycle requirements, and we will review the end effector, data collection and deployment approach.
Describe your application ↗EMBODIED AI DEVELOPMENT
Gen3.5 provides a complete embodied-AI workflow: collect human demonstrations, fine-tune a VLA model and deploy it back to the robot to follow natural-language instructions.
APPLICATIONS
An operator wearing a Meta Quest 3 headset teleoperates the arms by hand tracking while video and joint states are recorded.
Demonstrations are segmented, labelled with task instructions and converted between coordinate frames to form a training set.
The NVIDIA GR00T N1.7 foundation model is fine-tuned on a GPU server so the robot carries out pick-and-place tasks from natural-language instructions.
Inference runs on a server or the on-board Jetson AGX Orin, with commands sent over ROS 2. A browser-based HMI monitors status, controls the base and column and manages tasks.
SAFETY
SPECIFICATIONS
Values from the Lajiu Gen3.5 parameter sheet.
| Packed size (W × D × H) | 540 × 490 × 1,440 mm |
|---|---|
| Overall size · column raised | 540 × 490 × 1,795 mm |
| Overall size · column lowered | 540 × 490 × 1,395 mm |
| Total degrees of freedom | 15 (2 × 7-DOF arms + 1 lift; dexterous hands not counted) |
| Weight | 98 kg |
| Arm reach height | 0–2,088 mm (palm centre) |
| Degrees of freedom | 7 |
|---|---|
| Working radius | 840 mm |
| Payload | 5 kg |
| Repeatability | ±0.05 mm |
| Waist degrees of freedom | 1 |
|---|---|
| Column stroke | 400 mm |
| Lift speed | 55–80 mm/s |
| Column accuracy | 1 mm |
| Travel speed | 1.2 m/s |
|---|---|
| Drive | Omnidirectional two-wheel differential |
| Minimum aisle width | 63 cm |
| Slope | 10° |
| Gap / step | Gap ≤ 6 cm, step ≤ 2 cm |
| Compute module | Jetson AGX Orin 64 GB, 275 TOPS |
|---|
| Vision | RGB-D cameras: head ×1, chest ×2, wrists ×2 |
|---|---|
| Lidar | 360° horizontal, 0.22–40 m |
| Force sensing | Joint torque sensors (optional) |
| Configuration | OmniPicker (standard); dexterous hands (optional) |
|---|
| Type | NMC lithium, automatic recharging |
|---|---|
| Capacity | 30 Ah |
| Output voltage | 48 V |
| Runtime | 4–6 h |
| VLA, teleoperation, training environment | Supported |
|---|
| Warranty | 1 year (terms per contract) |
|---|---|
| Technical support | Provided by Lajiu |
Specifications: Lajiu Gen3.5 parameter sheet (October 2026). The product is under continuous development; the final configuration and specifications are those in the technical agreement issued with the quotation. Demonstration clips were filmed in research-test settings with people and third-party marks blurred; they illustrate functions and do not represent cycle times or success rates for a specific project.
FAQ
Each arm carries 5 kg with ±0.05 mm repeatability and an 840 mm working radius. The payload includes the end effector and the part, so optional tooling is checked against its actual mass.
Runtime is 4–6 hours from a 30 Ah, 48 V NMC lithium battery. Below 15% charge the robot returns to its charger automatically; recharging can also be triggered from the HMI or remote control.
Yes. The robot supports teleoperation data collection, a VLA training environment and ROS 2 interfaces, so models can be fine-tuned on your own task data and deployed to the robot. Development documentation and training scope are agreed per project.
OmniPicker grippers are standard and dexterous hands are optional. For other tooling, share the part, grasp method and mass so the interface and payload can be reviewed.
Enquiries from customers worldwide are welcome. Share the application, objects to handle, end-effector configuration, quantity and destination; price, lead time, shipping and service are confirmed in the quotation.
ENQUIRE / GEN3.5
Describe the application, the objects to handle (size and mass), site conditions, end-effector configuration (gripper or dexterous hands), quantity and destination, and whether you need data-collection and model-training support.